ISO 21423 opens the door for multi-vendor robot fleets
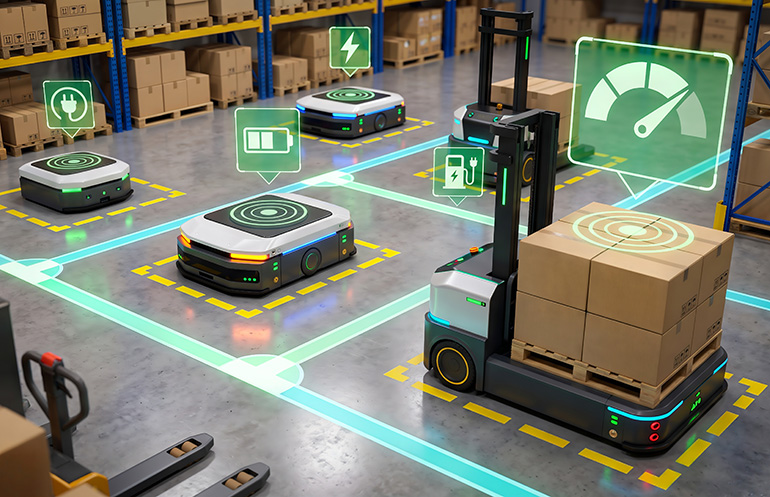
Running mobile robots from different manufacturers on the same facility floor usually meant carving the warehouse into rigid zones or paying an integrator to stitch proprietary fleet software together. The Association for Advancing Automation and ISO Technical Committee 299 have published ISO 21423:2026, creating an international standard for industrial mobile robots to exchange telemetry, status, and task availability regardless of vendor.
The standard covers robot-to-robot coordination, building systems such as automated doors and lifts, and external enterprise tools. Specifying how autonomous mobile robots and automated guided vehicles announce position, speed, and operational condition solves an immediate operational headache. When equipment shares a common format for spatial presence, facility bottlenecks clear up much faster than when two fleet managers fight over right-of-way blindly.
A shared messaging protocol does not solve coordination by itself. Telemetry format is the baseline, but real coordination requires clear rules for path arbitration and yielding priorities under load. If vendors adopt the protocol primarily as an export stream while reserving active traffic management for their closed platforms, buyers will still face friction. The real test is whether fleet vendors allow third-party units to negotiate active routing directly, rather than just broadcasting where they happen to be stuck.